Robotic Perception and Manipulation of Deformable Linear Objects
Deformable Linear Objects (DLOs) are a specific subset of Deformable Objects (DOs), i.e. objects that can change their shape when subjected to external forces. DLOs are characterized by a linear geometry and include examples such as wires, cables, strings, and ropes. Despite being common in both domestic and industrial environments, DLOs pose a significant challenge for robotic applications. Indeed, the manufacturing and assembly industries that work with wires and wiring harnesses still rely heavily on human labor. The main challenges that robots face when dealing with these objects are: (1) the lack of any specific shape or feature that distinguishes them from other objects; (2) the vast number of possible configurations they can assume; and (3) their highly nonlinear and complex dynamics, which are generally difficult to model and predict.
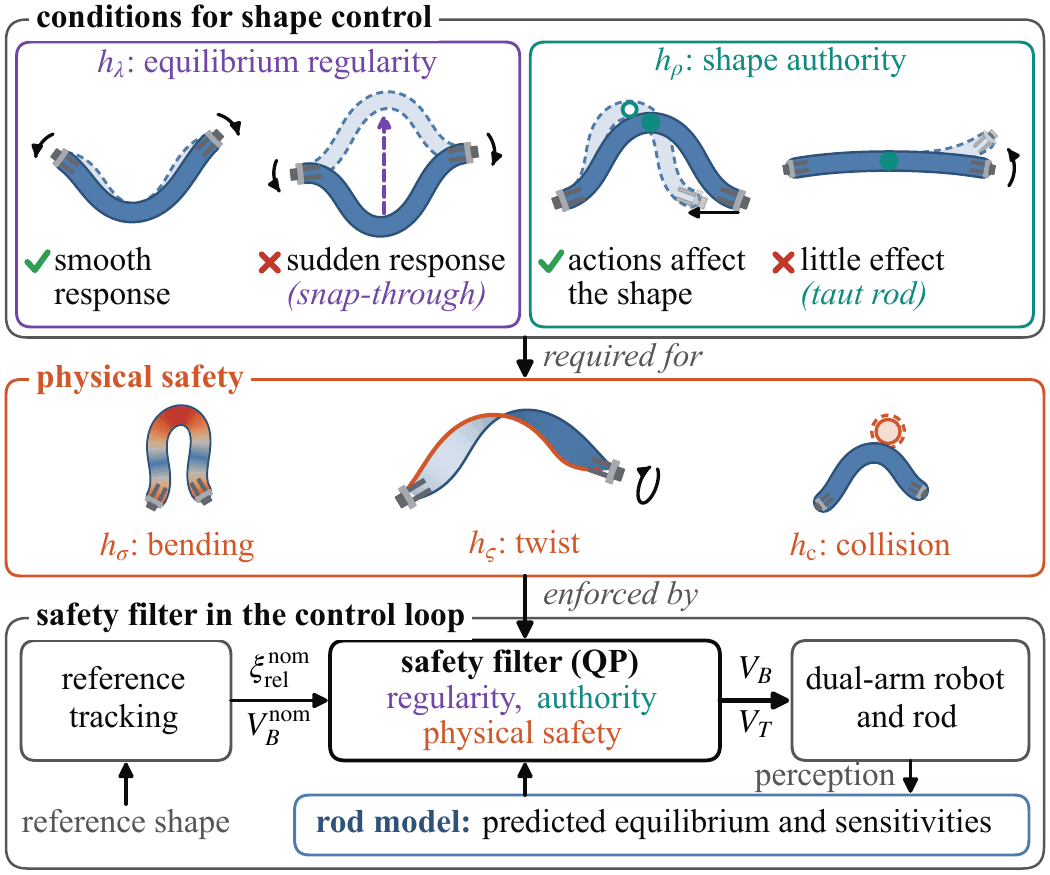
At LAR, we are actively researching approaches to effectively perceive DLOs using deep learning methods, while also developing smart strategies to enable the automatic generation of training datasets. For the robotic manipulation, our focus is on combining both model-based and learning-based approaches, with the aim of addressing some of their individual limitations.
Recent work extends this line to language-grounded perception, multi-view tracking, topology learning for the dual-arm manipulation of multiple cables, and complete robotic cells for connector assembly and wiring-harness manufacturing. We also reviewed the field in a survey and in a two-part tutorial on shape servoing of deformable objects.
- Survey & tutorials
- Dataset generation
- 2D perception
- 3D perception
- Manipulation
- Assembly & industry
- Cloth
Key publications
- JournalRobotic perception and manipulation of deformable linear objects: A surveyThe International Journal of Robotics Research, 2026
- PreprintA Tutorial on Shape Servoing of Deformable Objects-Part I: FundamentalsarXiv:2610.40559, 2026
- JournalVision and Tactile Sensing for DLO Manipulation and Pin Insertion in Robotic Connector AssemblyIEEE/ASME Transactions on Mechatronics, 2026
- JournalGNN Topology Representation Learning for Deformable Multi-Linear Objects Dual-Arm Robotic ManipulationIEEE Transactions on Automation Science and Engineering, 2025
- JournalRobotic Manipulation of Deformable Linear Objects via Multiview Model-Based Visual TrackingIEEE/ASME Transactions on Mechatronics, 2025
- JournalDLO Perceiver: Grounding Large Language Model for Deformable Linear Objects PerceptionIEEE Robotics and Automation Letters, 2024