Robotic Perception and Manipulation of Deformable Linear Objects
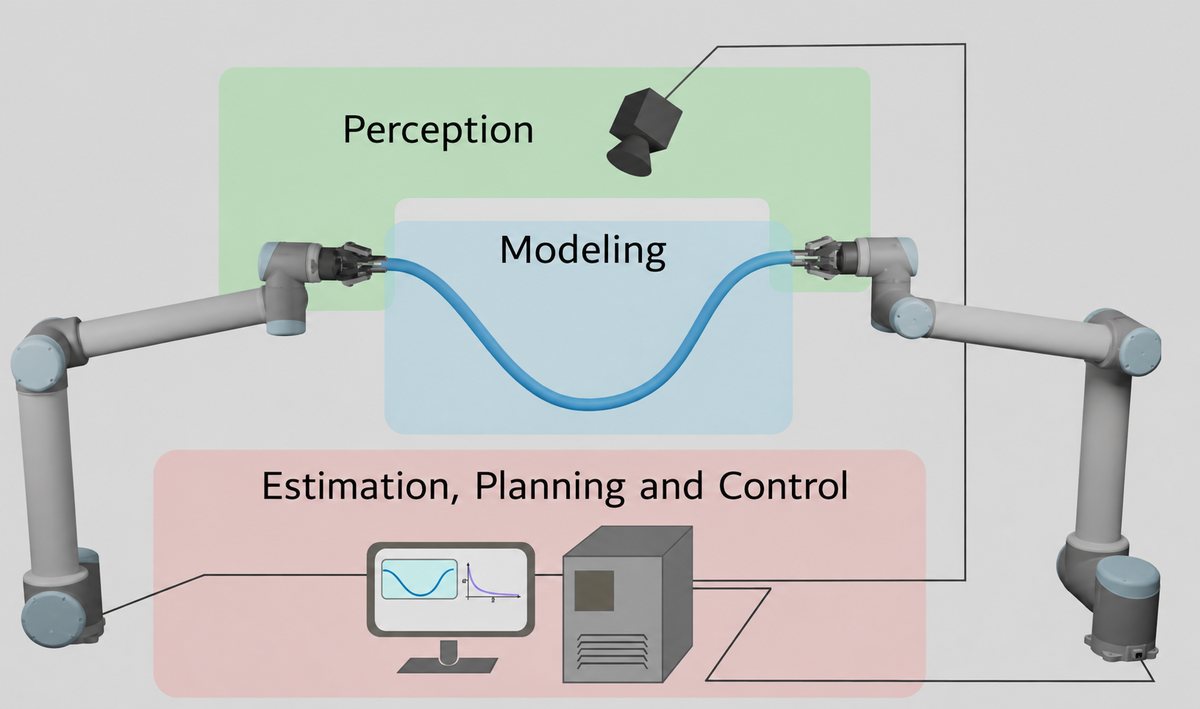
At LAR, we are actively researching approaches to effectively perceive DLOs using deep learning methods, while also developing smart strategies to enable the automatic generation of training datasets. For the robotic manipulation, our focus is on combining both model-based and learning-based approaches, with the aim of addressing some of their individual limitations.
01
Survey and Tutorials
3 papers
02
Vision-based Dataset Generation
4 papers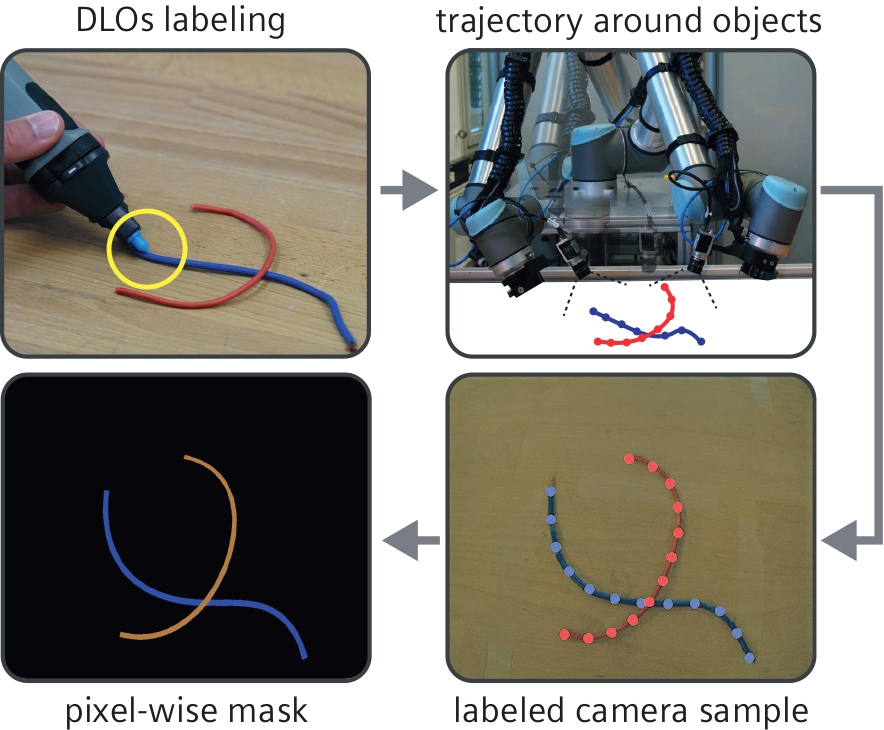
Deep-learning perception of deformable linear objects needs large labelled datasets, but annotating thin, deformable and often overlapping cables by hand is slow and error-prone. We develop strategies that generate training data with little manual effort: chroma-key acquisition with background replacement to obtain domain-independent images, semi-automatic labelling with a VR tracker that blends real and synthetic samples, dense annotations obtained from a few sparse inputs, and copy-and-paste augmentation for wiring-harness components.
Key papers
-
A Weakly Supervised Semi-Automatic Image Labeling Approach for Deformable Linear Objects
IEEE Robotics and Automation Letters, 2023
-
Auto-generated Wires Dataset for Semantic Segmentation with Domain-Independence
International Conference on Computer, Control and Robotics (ICCCR), 2021
More papers
-
Deformable Objects Perception is Just a Few Clicks Away – Dense Annotations from Sparse Inputs
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024
-
Copy and Paste Augmentation for Deformable Wiring Harness Bags Segmentation
IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2023
03
2D Perception
6 papers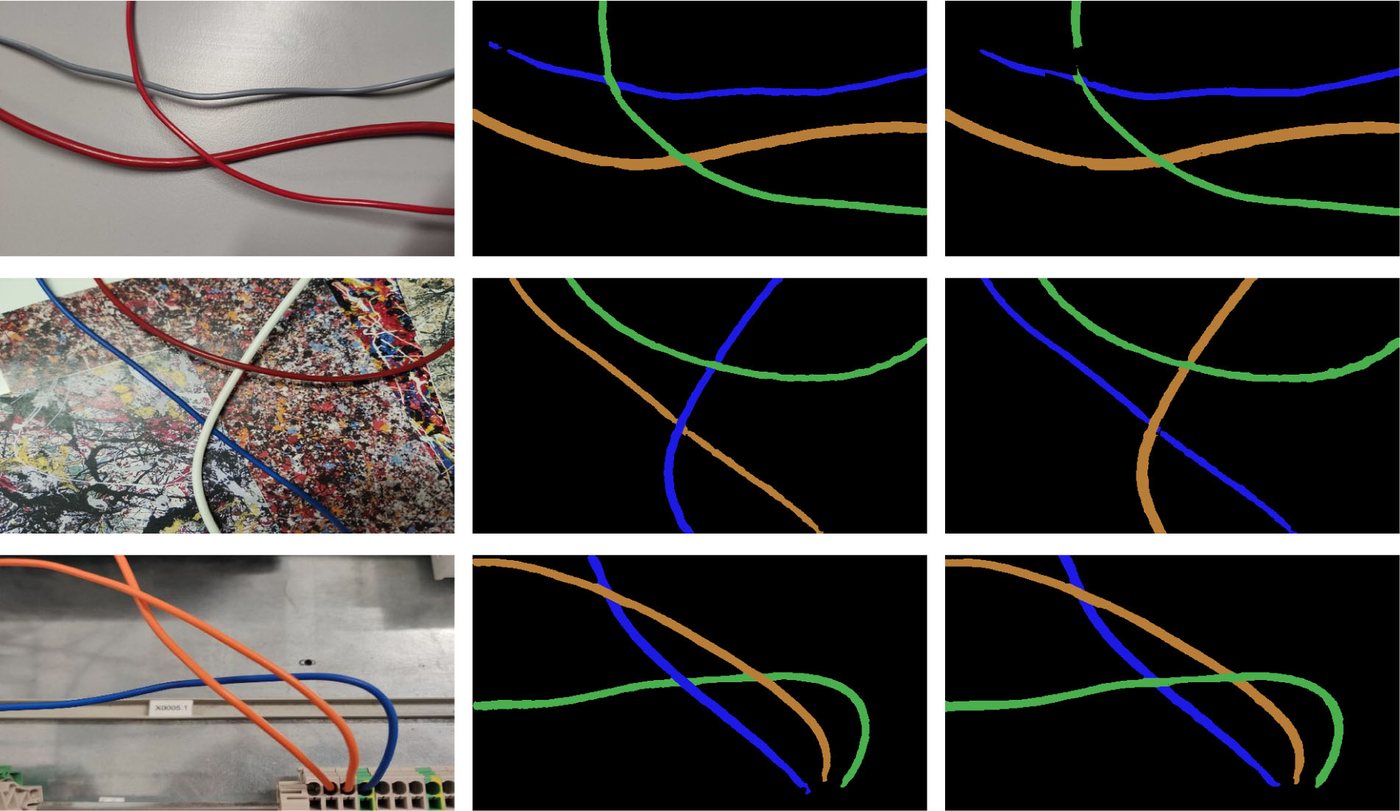
Cables and wires lack a distinctive shape, colour or texture, can take countless configurations and often cross each other, which makes them hard to segment for general-purpose detectors. We developed a family of instance-segmentation methods that combine deep networks for semantic segmentation with graph-based reasoning, separating each cable and describing it with a spline: Ariadne+ covers the binary mask with paths on a graph, FASTDLO solves the intersections with skeletonization and a similarity network at more than 20 FPS, and RT-DLO reasons on a graph of centre-line nodes in real time. DLO Perceiver segments the specific cable described by a text prompt, and we also estimate the orientation of the connector at the cable end from a single camera.
Key papers
-
DLO Perceiver: Grounding Large Language Model for Deformable Linear Objects Perception
IEEE Robotics and Automation Letters, 2024
-
RT-DLO: Real-Time Deformable Linear Objects Instance Segmentation
IEEE Transactions on Industrial Informatics, 2023
-
FASTDLO: Fast Deformable Linear Objects Instance Segmentation
IEEE Robotics and Automation Letters, 2022
-
Ariadne+: Deep Learning–Based Augmented Framework for the Instance Segmentation of Wires
IEEE Transactions on Industrial Informatics, 2022
More papers
-
Monocular Estimation of Connector Orientation: Combining Deformable Linear Object Priors and Smooth Angle Classification
IEEE International Conference on Advanced Intelligent Mechatronics (AIM), 2024
-
Let’s Take a Walk on Superpixels Graphs: Deformable Linear Objects Segmentation and Model Estimation
Lecture Notes in Computer Science (ACCV 2018), 2019
04
3D Perception
3 papers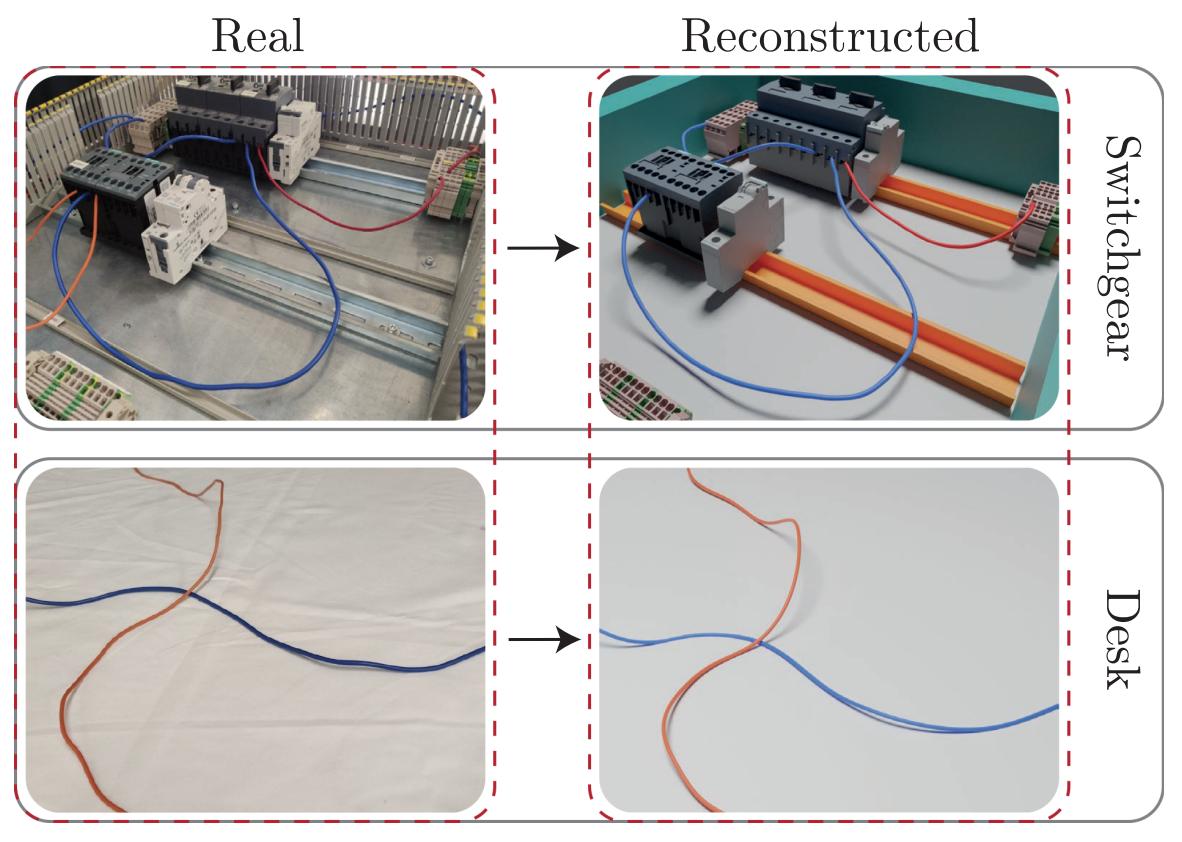
Grasping and manipulating cables requires knowing their shape in 3D. We estimate and track the 3D shape of deformable linear objects from multiple 2D views acquired by a compact camera mounted on the robot: key points extracted from each image are modelled with B-spline curves and matched across views with a multi-view stereo approach, reaching sub-millimetre accuracy, and multi-view model-based visual tracking closes the loop for the robotic manipulation of the cables.
Key papers
-
Robotic Manipulation of Deformable Linear Objects via Multiview Model-Based Visual Tracking
IEEE/ASME Transactions on Mechatronics, 2025
-
Deformable Linear Objects 3D Shape Estimation and Tracking From Multiple 2D Views
IEEE Robotics and Automation Letters, 2023
More papers
-
3D DLO Shape Detection and Grasp Planning from Multiple 2D Views
IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2021
05
Manipulation
7 papers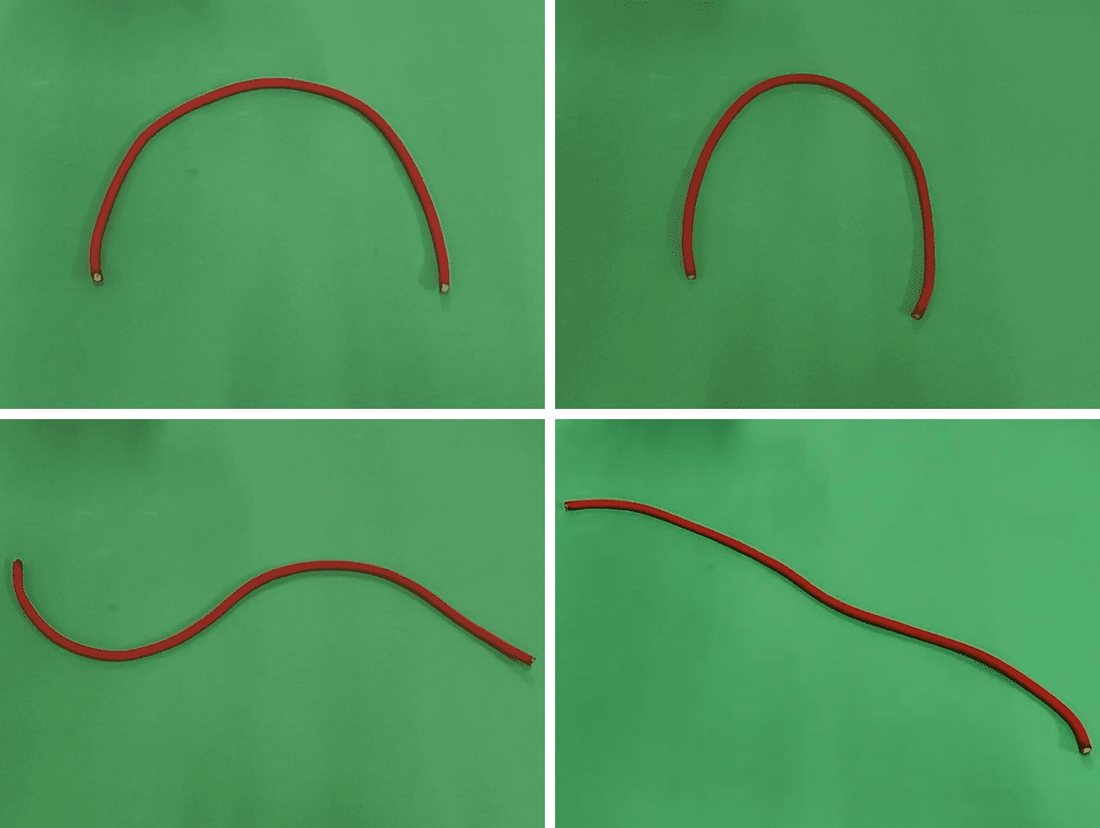
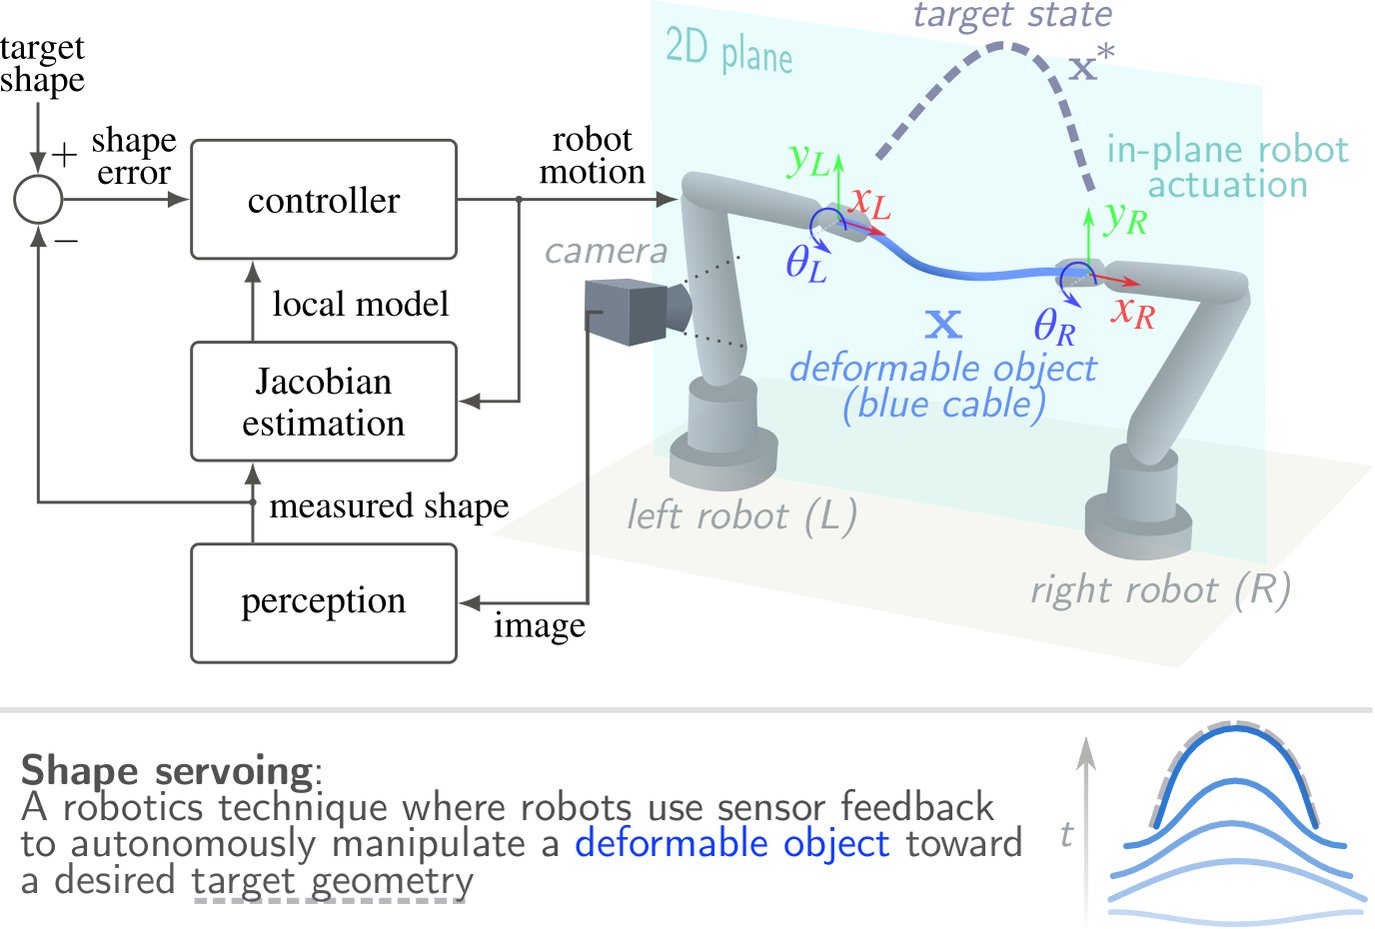
Manipulating cables is hard because of their unpredictable configuration, high-dimensional state and complex nonlinear dynamics. We combine model-based and learning-based approaches: neural-network models of the cable whose physical parameters are estimated online while the robot controls its shape, spline-based dynamic models, learning-based pipelines that reshape a cable in cluttered scenes, and shared-autonomy frameworks in which the robot assists a human operator.
Key papers
-
Deformable Linear Objects Manipulation With Online Model Parameters Estimation
IEEE Robotics and Automation Letters, 2024
More papers
-
A Vision-based Shared Autonomy Framework for Deformable Linear Objects Manipulation
2023 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2023
-
New model-based manipulation technique for reshaping deformable linear objects
The International Journal of Advanced Manufacturing Technology, 2021
-
Symplectic Integration for Multivariate Dynamic Spline-Based Model of Deformable Linear Objects
Journal of Computational and Nonlinear Dynamics, 2021
-
Validating DLO Models from Shape Observation
2021 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2021
-
Model-based Manipulation of Deformable Linear Objects by Multivariate Dynamic Splines
2020 IEEE Conference on Industrial Cyberphysical Systems (ICPS), 2020
06
Robotic Assembly and Industrial Applications
15 papers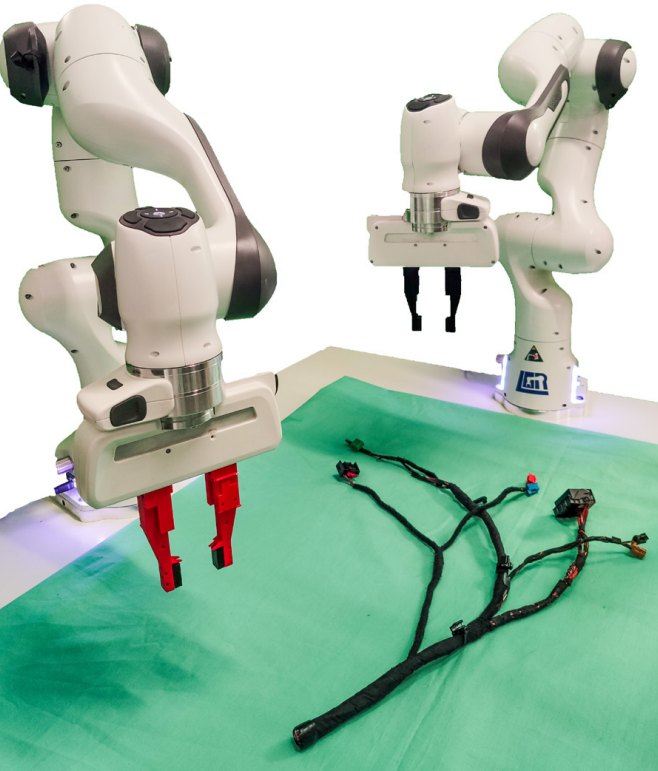
From perception and planning to complete robotic cells: wire and pin insertion in connectors with vision and tactile sensing, dual-arm systems for wiring-harness manufacturing and for handling several cables at once through graph-neural-network representations of their topology, switchgear cabling, and the manipulation and quality check of medical hoses.
Key papers
-
Vision and Tactile Sensing for DLO Manipulation and Pin Insertion in Robotic Connector Assembly
IEEE/ASME Transactions on Mechatronics, 2026
-
Mechatronic Integration of a Dual-Arm Robotic System for Wiring Harness Manufacturing
IEEE/ASME Transactions on Mechatronics, 2025
-
GNN Topology Representation Learning for Deformable Multi-Linear Objects Dual-Arm Robotic Manipulation
IEEE Transactions on Automation Science and Engineering, 2025
More papers
-
A Dual-Arm Robotic System for Autonomous Connector Assembly via Vision-Tactile Sensing and Contact-Based Pose Refinement
2026 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2026
-
A Robotic System for Medical Hoses Manipulation and Quality Check
IEEE Transactions on Automation Science and Engineering, 2025
-
Towards Automated Connector Assembly: Wire Insertion Combining Tactile and Vision Sensors
2025 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2025
-
Design and Integration of a Robotic Gripper and Warehouse System for Automated Cable Assembly
2025 IEEE 21st International Conference on Automation Science and Engineering (CASE), 2025
-
Scalable Shared Encoding Architecture for Learning-Based Error Detection in Robotic Wiring Harness Assembly
2024 IEEE International Conference on Advanced Intelligent Mechatronics (AIM), 2024
-
Cable Detection and Manipulation for DLO-in-Hole Assembly Tasks
2022 IEEE 5th International Conference on Industrial Cyber-Physical Systems (ICPS), 2022
-
Robotic Wires Manipulation for Switchgear Cabling and Wiring Harness Manufacturing
2021 4th IEEE International Conference on Industrial Cyber-Physical Systems (ICPS), 2021
-
Deformable Objects Grasping and Shape Detection with Tactile Fingers and Industrial Grippers
2021 4th IEEE International Conference on Industrial Cyber-Physical Systems (ICPS), 2021
-
Combining Vision and Tactile Data for Cable Grasping
2021 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2021
-
DLO-in-Hole for Assembly Tasks with Tactile Feedback and LSTM Networks
2019 6th International Conference on Control, Decision and Information Technologies (CoDIT), 2019
-
Automatized Switchgear Wiring: An Outline of the WIRES Experiment Results
Springer Tracts in Advanced Robotics, 2019
07
Cloth and Other Deformable Objects
3 papersSeveral of our perception and manipulation methods extend beyond linear objects, to cloth and garments.
Papers
-
Attention-Based Cloth Manipulation from Model-free Topological Representation
2024 IEEE International Conference on Robotics and Automation (ICRA), 2024
-
A Cyber-Physical System for Clothes Detection, Manipulation and Washing Machine Loading
2021 4th IEEE International Conference on Industrial Cyber-Physical Systems (ICPS), 2021
-
Pointcloud-based Identification of Optimal Grasping Poses for Cloth-like Deformable Objects
2020 25th IEEE International Conference on Emerging Technologies and Factory Automation (ETFA), 2020